Rob Boyd
I build and iterate on models — mostly computer vision and structured sequence prediction. The work below is where I spend my time: competitive benchmarks with a hard metric, real video and sensor data, and long experiment loops where the representation matters more than the tuning.
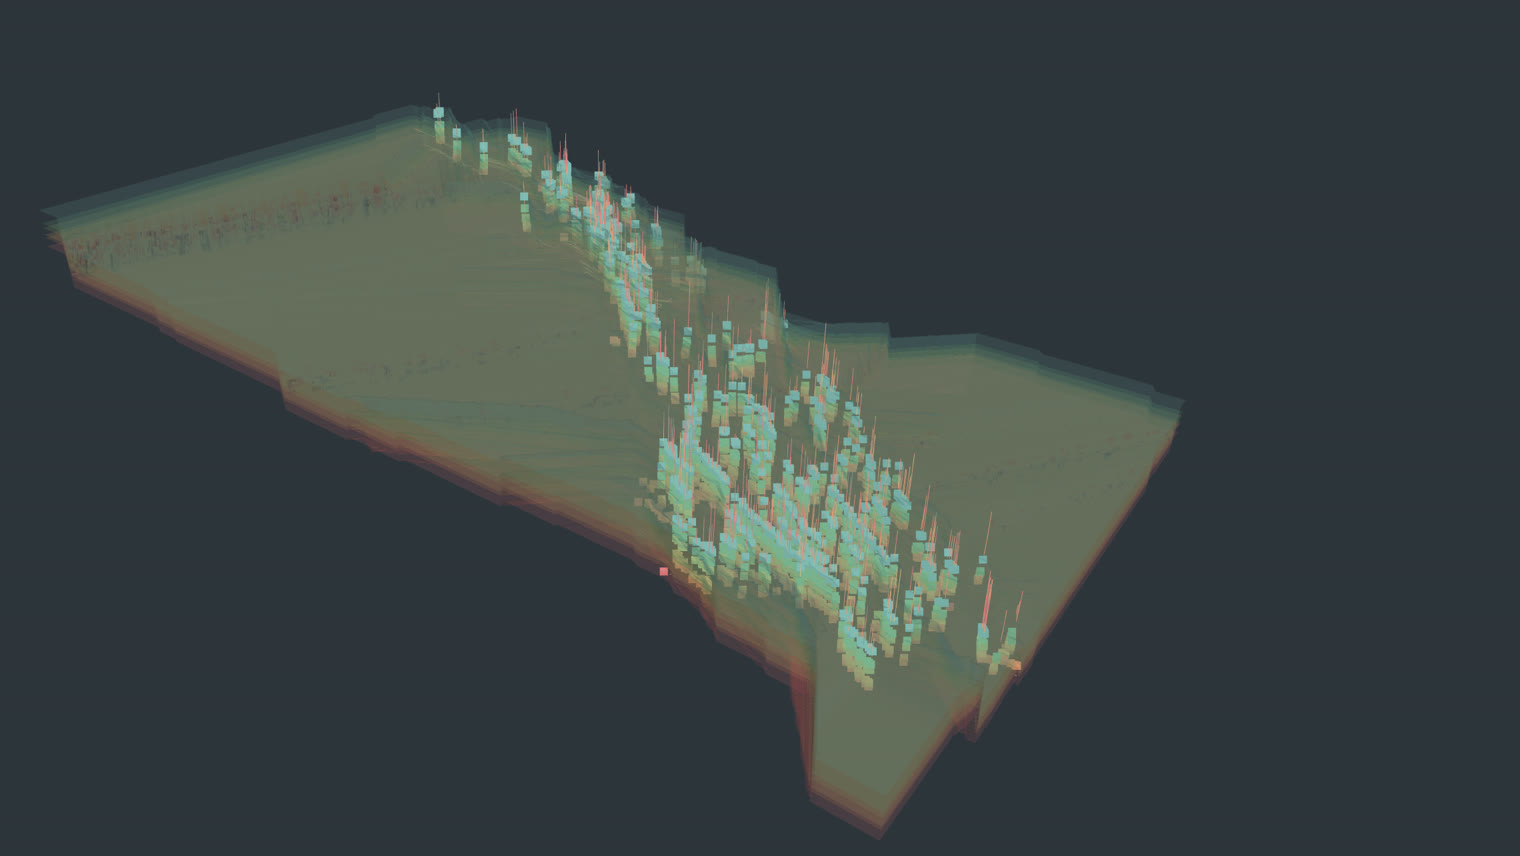
Subsurface geology prediction — ROGII / Kaggle
Predicting where a drill bit sits inside a stratigraphic column from gamma-ray logs alone. A full-well Transformer with a monotone CRF, an ensemble of particle filters and geometry priors, and one architectural idea worth more than everything else combined: stop averaging decoded paths, and pool the posteriors before you collapse them. Includes a live 3D viewer of the reconstructed subsurface.
Finished 18th on the public leaderboard and 189th on the private one — the write-up includes an honest account of why.
Tennis video understanding
A full broadcast-video pipeline: TrackNet ball tracking, a 10-channel court keypoint heatmap model, pose estimation, and two event-detection heads — resolved into court coordinates, in/out calls, serve speeds and rally statistics.
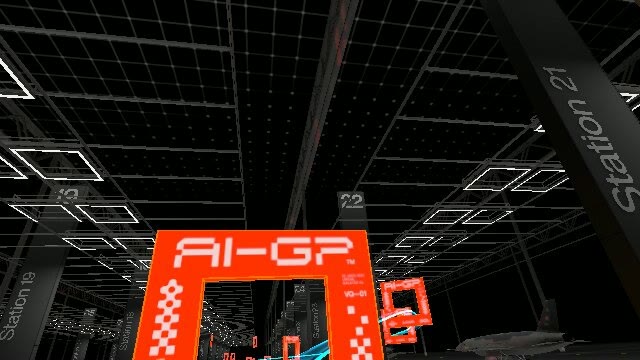
Autonomous drone racing — Anduril AI Grand Prix
Reinforcement learning for a 5-inch racing quad flying a gate course with no human pilot. Built an open-source practice simulator — real Betaflight firmware in lockstep with 6-DOF physics — then trained control policies up a bounded speed ladder from 2.7 m/s toward 22 m/s. Includes video of a complete seventeen-gate run.